Motor Error Handling
In this tutorial we will learn about errors that the motor itself detects and reports, and how to handle them from the SDKs perspective.
Prerequisites
(Optional) We recommend reading the ORCA Series Reference Manual’s section “Errors”. The reference manual can be found on our downloads page.
Motor Errors Intro
Motor errors here refers to errors that an ORCA motor detects internally. They can arise when the motor detects a variety of situations which it deems incorrect for normal operation. As a safety precaution, when a motor error is active the motor will typically not output any force until the error is cleared.
These errors can be seen in the IrisControls GUI in the “Active Errors” field found in the status bar at the top of the window. When an error is active the value of this field will be a bright red.
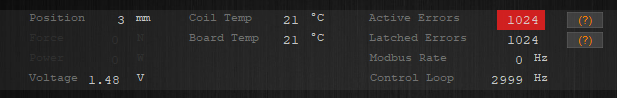
This image shows a motor thats displaying a 1024 error. Upon reading the reference manual (or clicking the question mark button) we can determine that this error is reporting an invalid supply voltage. Indeed if we look at our “Voltage” field in the same status bar, we can see that our motor is detecting 1.48 volts, which is below the necessary supply voltage for operating an ORCA motor.
The image also displays a 1024 error in the “Latched Errors” field. This field is merely there to report all errors which have occured since the last time this register was cleared. A non-zero value listed here does not mean that your motor is actively encountering the errors listed.
Detecting Errors with the SDK
We’ll start with the following code as our baseline:
#include <iostream>
#include "actuator.h"

using namespace orcaSDK ;

int main() {
	Actuator motor;

	int serial_port;
	std::cout << "Please input the serial port number of your connected motor. ";
	std::cin >> serial_port;

	motor.open_serial_port(serial_port);

	return 0;
}
from pyorcasdk import Actuator

motor = Actuator()

serial_port = int(input("Please input the serial port number of your connected motor. "))

motor.open_serial_port(serial_port)
In order to access the active errors of a motor, we can call the Actuator.get_errors() method.
...
OrcaResult<uint16_t> motor_errors_result = motor.get_errors();

if (motor_errors_result.error)
{
        std::cout << "Failed to read active errors: " << motor_errors_result.error.what() << "\n";
        return 1;
}

std::cout << "Active motor errors: " << motor_errors_result.value << "\n";
...
import sys
...
motor_errors_result = motor.get_errors()

if motor_errors_result.error:
        print("Failed to read active errors: " + motor_errors_result.error.what())
        sys.exit(1)

print("Active motor errors: " + str(motor_errors_result.value))
...
Note
Note that motor errors are distinct from OrcaError objects handled in the SDK. If motor_errors_result.error evaluates to true in this code block, it means that there was an issue communicating with your motor, not that your motor itself has encountered an error. In this case, motor_errors_result.value is what contains the actual motor errors.
Give this code a try! Try running this program with the motor connected to an active power supply and with the motor unpowered. See how the results change!
Extracting Individual Errors
There are multiple errors that your motor might encounter, and some of these errors may be encountered simultaneously. However, calling Actuator.get_errors() only returns one value. Each individual error is reported by a single bit/flag within the active errors register. As an example, this is what the error value would be if you were encountering both a 1024 (invalid voltage) and 512 (poor shaft quality) error at the same time:
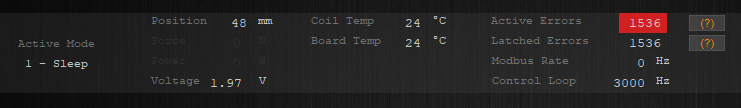
If our code needs to detect when our motor has encountered an invalid supply voltage error but another error was present, then simply comparing the Actuator.get_errors() return value to the error we’re interested in (1024) could fail. Because each error is reported using a single bit, extracting a specific error can be achieved by performing a bitwise AND on the error value with the error bit that you’re interested in.
...
if (motor_errors_result.value & 1024) ... // GOOD: There is definitely a 1024 error
if (motor_errors_result.value == 1024) ... // BAD: Will fail if multiple active errors
...
...
if motor_errors_result.value & 1024: # GOOD: There is definitely a 1024 error
        ...
if motor_errors_result.value == 1024: # BAD: Will fail if multiple active errors
        ...
...
Note that we use the literal int 1024 here, but more descriptive names for each error type (along with all ORCA register info) can be found in the pyorcasdk.orca_registers module. Here is an equivalent example using this module:
if (motor_errors_result.value & ORCAReg::ERROR_0_Values::VOLTAGE_INVALID_Mask) ...
import pyorcasdk.orca_registers as orca_reg
...
if motor_errors_result.value & orca_reg.ERROR_0_VOLTAGE_INVALID_Mask:
        ...
Clearing Active Errors
Because the motor will not produce force while active errors are present, any active errors will need to be cleared before the motor can be used again.
Some errors are transient, and disappear when the condition that caused them to appear is removed. For example an invalid supply voltage error will disappear when the motor receives power from a valid power supply.
Some errors, however, will remain active after the event that triggered them has passed. For example, if a motor has stopped operating due to exceeding its max temperature (error 64), then the error will need to be manually cleared after the motor has cooled down.
These persistent errors can be cleared either by setting the motor to Sleep Mode, or by calling the Actuator.clear_errors() function. If either option is available to you, prefer setting the motor to Sleep Mode over calling Actuator.clear_errors() directly.
...
motor.set_mode(MotorMode::SleepMode); // Prefer this
motor.clear_errors();                 // But this works too
...
from pyorcasdk import MotorMode
...
motor.set_mode(MotorMode.SleepMode) # Prefer this
motor.clear_errors()                # But this works too
...
Complete Example
#include <iostream>
#include "actuator.h"

using namespace orcaSDK;

int main() {
	Actuator motor;

	int serial_port;
	std::cout << "Please input the serial port number of your connected motor. ";
	std::cin >> serial_port;

	motor.open_serial_port(serial_port);

	OrcaResult<uint16_t> motor_errors_result = motor.get_errors();

	if (motor_errors_result.error)
	{
		std::cout << "Failed to read active errors: " << motor_errors_result.error.what() << "\n";
		return 1;
	}

	std::cout << "Active motor errors: " << motor_errors_result.value << "\n";

	if (motor_errors_result.value & ORCAReg::ERROR_0_Values::VOLTAGE_INVALID_Mask) std::cout << "There is definitely an invalid supply voltage error!" << "\n";

	motor.set_mode(MotorMode::SleepMode); // Try to clear active errors

	return 0;
}
from pyorcasdk import Actuator, MotorMode
import pyorcasdk.orca_registers as orca_reg
import sys

motor = Actuator( "MyMotorName" )

serial_port = int(input("Please input the serial port number of your connected motor. "))

serial_port_error = motor.open_serial_port(serial_port)

motor_errors_result = motor.get_errors()

if motor_errors_result.error:
	print("Failed to read active errors: " + motor_errors_result.error.what())
	sys.exit(1)

print("Active motor errors: " + str(motor_errors_result.value))

if (motor_errors_result.value & orca_reg.ERROR_0_VOLTAGE_INVALID_Mask):
	print("There is definitely an invalid supply voltage error!")

motor.set_mode(MotorMode.SleepMode) # Try to clear active errors